Autonomous mobile robots
Exploring robots that understand their surroundings and move through changing industrial environments.
- SLAM-based navigation
- Fleet coordination
- Dynamic obstacle avoidance
Inside the lab / Research & development
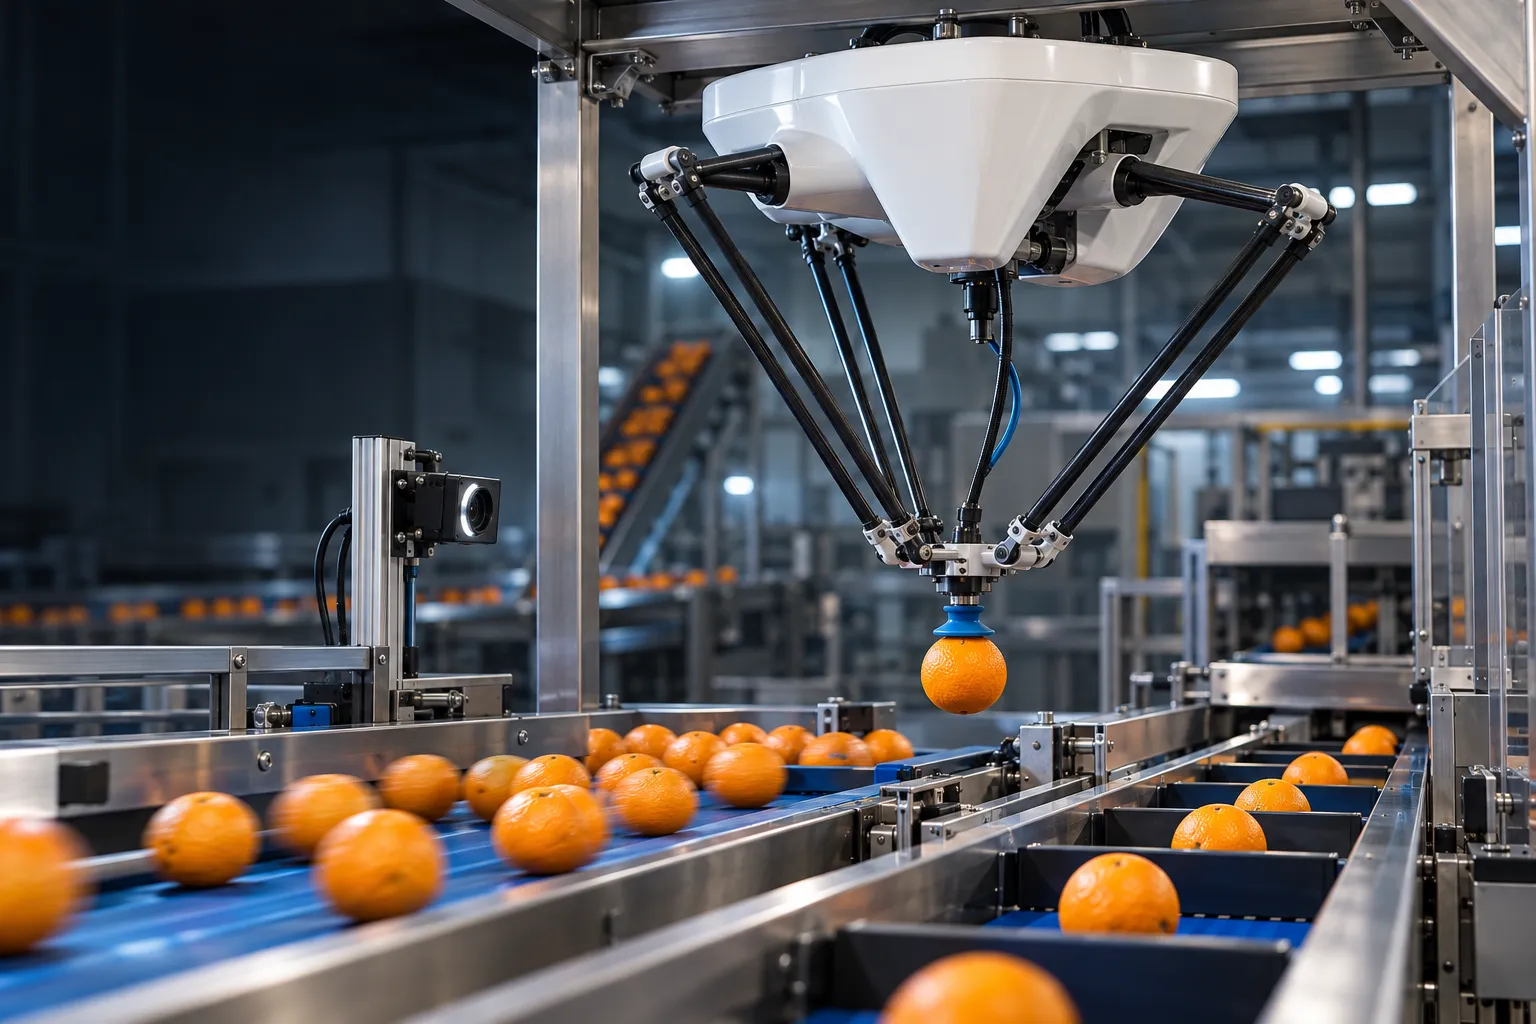
Alongside our computer vision solutions, our R&D explores how machines can use visual information to move and act. Delta robots, autonomous navigation, and manipulation are research directions for future agricultural and industrial applications.
01 / Research directions
Three connected areas of research, working toward a shared ambition: more capable, adaptable agricultural and industrial systems.
Exploring robots that understand their surroundings and move through changing industrial environments.
Researching how computer vision can guide precision movement for sorting, material handling, and collaborative applications.
Using NVIDIA Isaac Sim to explore behaviors, generate synthetic data, and evaluate systems in virtual environments.
02 / In development
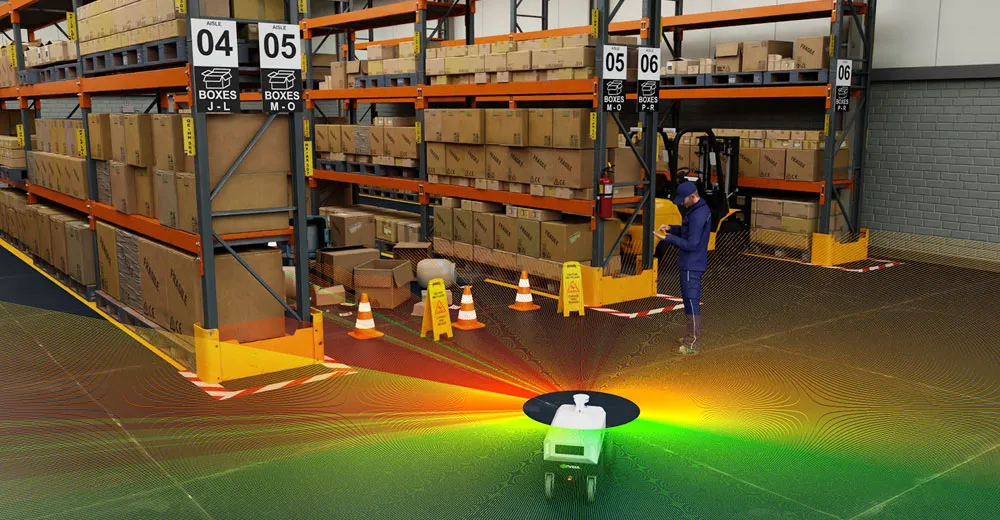
Simultaneous localization and mapping — SLAM — helps a robot build a map while understanding its own position. Our research combines navigation with perception to explore movement through dynamic factory floors.
Train and evaluate behaviors in digital twin environments before bringing them to physical systems.
Explore obstacle detection, changing routes, and navigation beyond fixed paths.
Research in progress. Our robotics work is an investment in future capabilities. We welcome research partnerships, pilot programs, and early adopter collaborations.
One connected vision
What we learn in simulation, perception, and autonomous systems informs our computer vision work. Explore the inspection and machine integration solutions we develop around your needs today.
Explore computer vision solutionsLet’s explore the possibilities
Have a research challenge, a pilot in mind, or a shared ambition? Let’s connect.